プラスチック顆粒自動計量包装機
Gaoxin のプラスチック顆粒自動計量および包装機は、顆粒材料を均質化し、正確に計量し、自動的に包装するように特別に設計されています。このプロセスはプラスチック生産における重要な後工程であり、製品の品質安定性、倉庫保管と物流の効率、そして最終的には市場競争力に直接影響します。
-

-
GAOXIN プラスチック顆粒自動計量および包装機 — PE、PP、PVC、ABS、PS、エンジニアリング プラスチックおよびリサイクル ペレットの造粒後の均質化、高速計量、無塵袋詰めのためのターンキー ソリューションです。
主な利点とセールスポイント
1. 優れた均一性を実現する統合均質化
バッチ間およびバッチ内の色/性能のばらつきを排除します。
ハイエンドのアプリケーションと厳しい色要件に対して一貫した品質を保証します。
リサイクルペレットまたはマスターバッチペレット用のオプションのマルチホッパーブレンド。
2. 高速・高精度計量
精度: ±0.1% ~ 0.2% (例: 25kg/袋)。
能力: 最大 800 ~ 1200 袋/時間 (半自動) または 1800 ~ 2200 袋/時間 (全自動)。
製品の無償提供と原材料の無駄を削減します。
3. 多彩な袋詰めと密封のオプション
織袋、紙プラスチック複合袋、バルブ袋に対応します。
ヒートシール/縫製/超音波シールモジュールを内蔵。
25kg、50kg、またはカスタム重量の間で素早い切り替えが可能です。
4. 自動搬送とパレタイジングの統合
袋平坦化機、金属探知機、重量チェッカー、ロボットパレタイザーに直接接続します。
造粒機からトラックへの積み込みまで、倉庫保管と物流の効率を合理化します。
5. 防塵、低メンテナンス設計
完全に密閉された空気圧またはサーボ駆動システム。
ペレットの流出、粉塵爆発のリスク、清掃のダウンタイムを削減します。
さまざまなペレットタイプ (ABS、PP、PVC など) のレシピストレージを備えたタッチスクリーン HMI。
6. 市場で実証済みの ROI
人件費の削減 (1 人のオペレーターで 2 ~ 3 ラインを実行可能)。
納期厳守が向上し、重量や色の違いによる顧客の拒否が減ります。
一貫した追跡可能な袋詰め製品により市場パフォーマンスを向上させます。
プラスチックの完全な均質化、計量、梱包
システムは次のコンポーネントで構成されます。
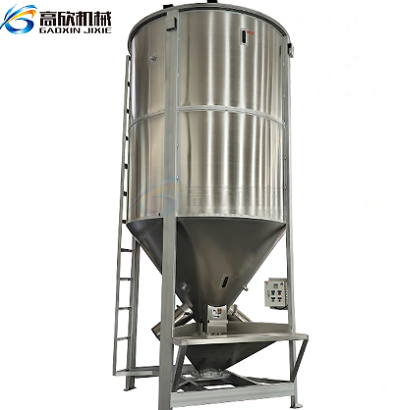
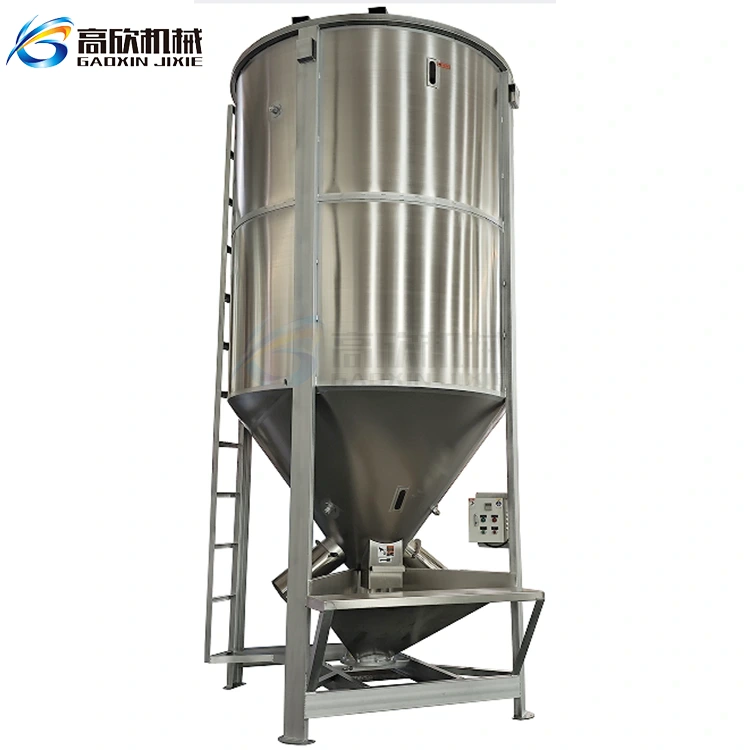
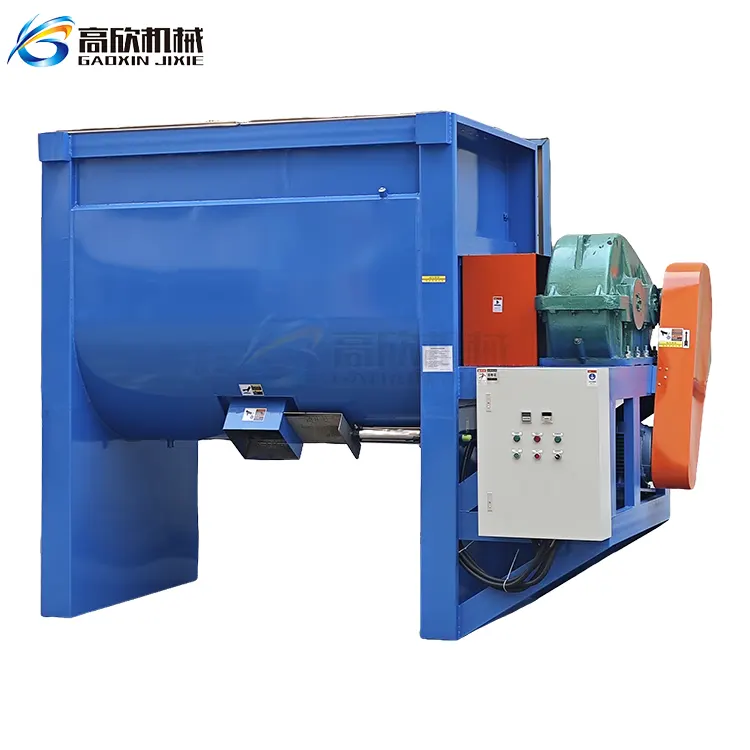
1. 均質化 (予混合): 上流の材料は、昇降装置 (エレベーターや空気圧搬送システムなど) を介して大型の保管サイロまたは混合ビンに輸送されます。容器内に撹拌装置を設置して粒子を予備混合し、粒子サイズ、色、または比率の変動を減らし、その後の正確な計量のために均一な材料を提供することができます。
2. 自動計量:均一な材料は、供給機構(ベルトコンベア、スクリューフィーダー、振動フィーダーなど)を介して計量ホッパーに供給されます。高精度計量センサーとインテリジェント制御システム (通常は PLC または専用計量器) が、高速、中速、低速の 3 段階の供給モードを制御し、高速かつ正確な計量を保証し、エラーを効果的に削減します。
3. Bagging and Clamping: When the weight meets the target, the system generates a signal.オペレーターがバッグを装着する (またはロボットアームが自動的にバッグを取り外して装着する) と、装置が自動的にバッグの開口部をクランプして、粉塵の流出を防ぎ、正確なバッグの配置を保証します。 4. Filling and Compacting: The discharge door below the weighing hopper opens, and the material is poured into the bag.一部の設備には、袋詰めした材料を振って圧縮し、袋内の空気を追い出し、袋詰め容量を増やし、積み重ねて輸送するために袋の形状を平らにするための圧縮装置または叩打装置が装備されています。
5. シールと搬送: 充填された袋は、ベルトコンベアによって自動的にシーム機、ヒートシーラー、またはバンディング機に搬送され、シールされます。 The conveyor belt then transports the finished bags to a designated area for palletizing or direct loading.
自動押出造粒生産ライン - 事例紹介


プラスチック造粒ワークショップ
原料保管、自動搬送、ロスレス均質化、混合、選別、計量、包装の自動化システム

自動プラスチック造粒ワークショップ
原料保管~自動搬送~ロスなく均質化~混合~選別~計量包装自動化システム

押出造粒自動化ワークショップ
お問い合わせを送信
連絡先情報
-
住所
中国広東省東莞市東坑鎮亭港南路6号
-
-
お見積りやご協力に関するお問い合わせは、メールまたは下記お問い合わせフォームよりお気軽にどうぞ。弊社営業担当より24時間以内にご連絡させていただきます。


ニュースのおすすめ